Skip to content
Home

Perception & ML

Perception on real automotive hardware. At Bosch I took UWB radar kick detection from first data to series development; before that, camera-radar fusion at Fraunhofer IVI and detector validation for a Formula Student driverless car.

At Bosch

Confidential work, told at public depth: what was built and what came of it.

Robert Bosch GmbH · Feb 2025 to Sep 2026 · internship, then thesis and series development

Radar kick detection at Bosch

Robert Bosch GmbH · Oct 2025 to Sep 2026

Hands-free tailgate opening, sensed by the digital-key radar already in the car. Its architecture is filed as an internal invention disclosure at Bosch.

  1. THESISMaster's thesis · Oct 2025 to Mar 2026

    Data, model, detection system and a live demonstrator.

  2. SERIESSeries development · Apr to Sep 2026

    A customer vehicle, robustness, the OEM design review, series hand-over, and the team's tools.

the whole build, from the first campaign to the hand-over
<7 months
RAM budget for the whole function, set by the microcontroller target
~100 KB
tailgate opensexisting digital-key radarkickkick zone

Drawn to explain; not Bosch data.

The internship came first. Its signal-analysis tool, its labelling flow and what it taught about the sensor carried into the thesis.

UWB radar evaluation and tooling

Robert Bosch GmbH · Internship · Feb 2025 to Sep 2025

Radar evaluation and tooling for Perfectly Keyless, Bosch's phone-as-key vehicle access system: measurement campaigns, hardware evaluation on real devices, and a labelling workflow, built for the kick-detection project, that became the team's standard.

signal analysis per measurement
1-2 h → seconds
label cleanup per campaign, down from hundreds
10-15 h
CIR analyser · Tapsrefresh rateradar rateparameters …magnitudephasemagnitude stdphase stdmagnitude SNRphase SNRtap 1magphasestdSNRtap 2magphasestdSNRtap 3magphasestdSNRtap 4magphasestdSNRtap 5magphasestdSNRtap 6magphasestdSNRCIR analyser · Tapsrefresh rateradar rateparameters …magnitudephasemagnitude stdphase stdmagnitude SNRphase SNRtap 1magphasestdSNRtap 2magphasestdSNRtap 3magphasestdSNRtap 4magphasestdSNRtap 5magphasestdSNRtap 6magphasestdSNR
The real-time CIR analyser I built: per-tap magnitude, phase and noise, with a stored reference overlaidKindSchematic, illustrative signalsSourceDrawn for this site

Open work

Public code and measured results.

Camera-radar fusion and tracking

Fraunhofer IVI · Mar 2024 to Jun 2024

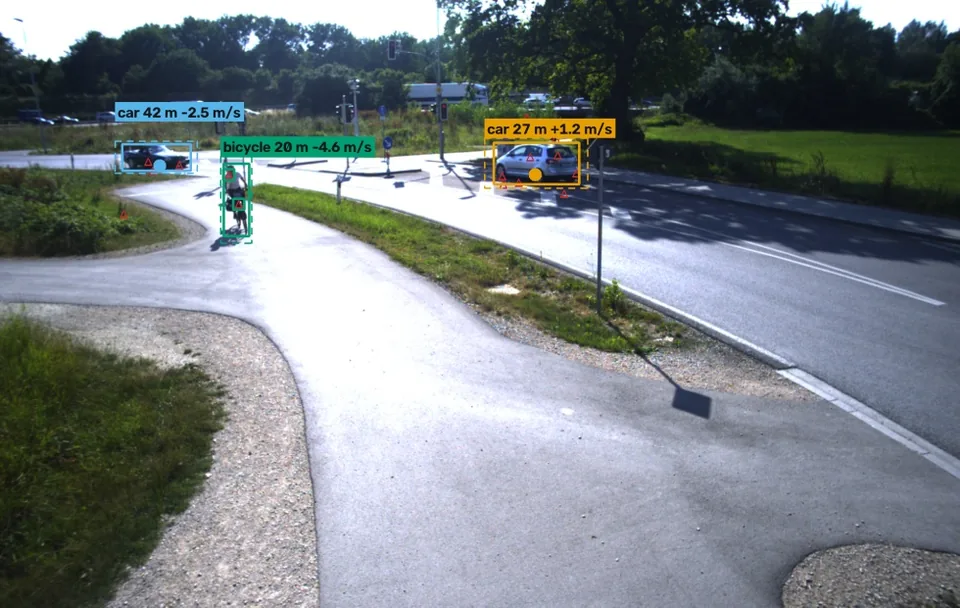
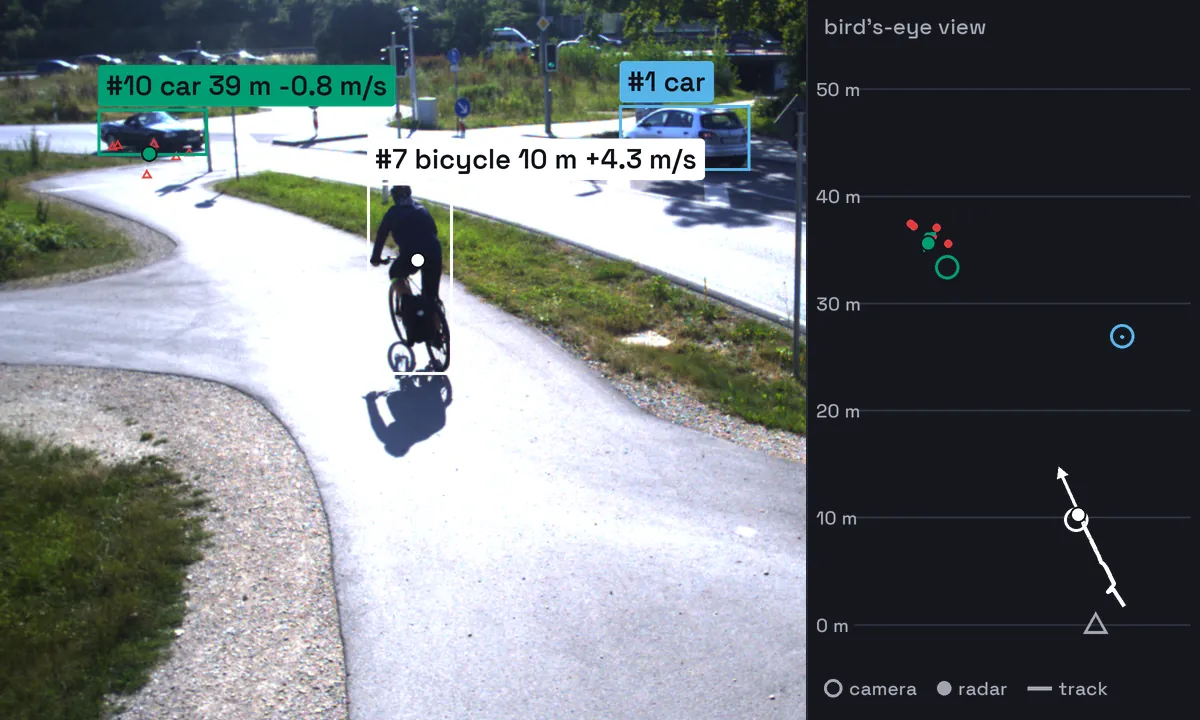
Camera and radar fused on real roadside recordings at Fraunhofer IVI. I led a student team of four and the technical work, and in 2026 extended it with a tracker and a full evaluation.

A roadside junction: a cyclist and two cars in detection boxes, each labelled with its track ID and the radar's range and speed
Fusion and tracking, camera viewSourceSensor-Data-Fusion, 2026LicenceINFRA-3DRC by Fraunhofer IVI, CC BY-NC 4.0

Validating a keypoint detector without new labels

Schanzer Racing Electric, Formula Student Driverless · Oct 2024 to Apr 2025

I led the validation of a driverless race car's cone-keypoint detector, with the outlines of existing segmentation masks as ground truth.

teams' cars and cameras in the validation data
40+
of manual keypoint labelling avoided
~100 h
One cone three times: the camera image, the outline traced from its FSOCO mask, and the predicted keypoints scored by their distance to that outline
One cone's keypoints, scored against its mask outlineSourceCone-Pose-Validation, FSOCO images